Lab notebook · Vol. 01

Peixing You manipulation · locomotion · navigation · dexterous hand · RL · LLMs · AI agent systems

I’m a Robotics M.S. student at UC San Diego focused on robot manipulation, reinforcement learning, perception, and sim-to-real. My recent work includes dexterous in-hand rotation, where I train and evaluate RL policies in simulation for controlled object reorientation, alongside humanoid control, teleoperation, RGB-D grasping, and state-estimation projects. I am also interested in LLM interpretation and post-training, knowledge editing, and multi-agent system applications.

  • Education
    MS Robotics, UC San Diego (GPA 3.8)
    BS MSE + BS CS, Tsinghua University
  • Focus Manipulation, locomotion, navigation, dexterous hand, RL, LLM post-training, AI agent systems
  • Highlight EWNA 2026 First Prize · NeurIPS 2022 Spotlight · IEEE CYBER 2024 Best Poster
  • Based in San Diego, CA

About

Field notes
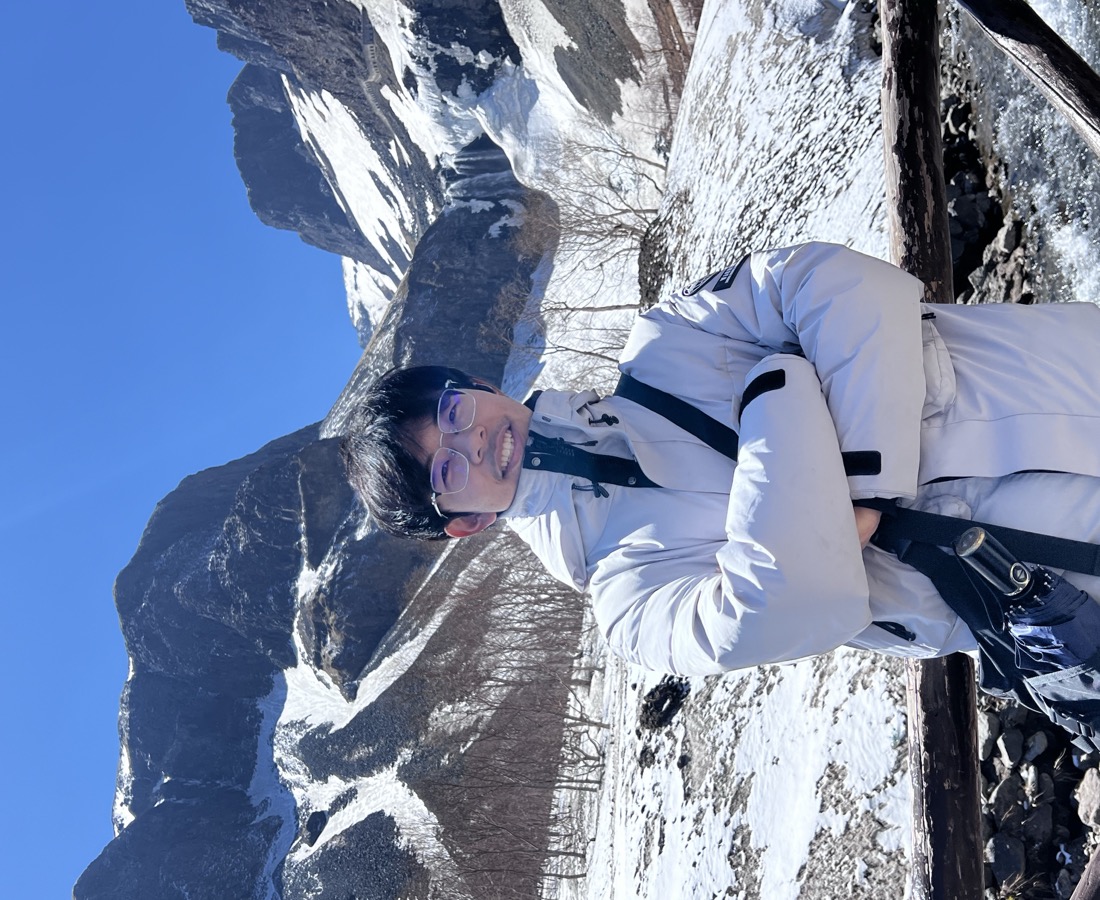
Portrait of Peixing You

I’m advised by Prof. Xiaolong Wang at UC San Diego, with dual bachelor’s degrees in Materials Science and Computer Science from Tsinghua University. I work on robot manipulation, reinforcement learning, perception, and transferring policies from simulation into controlled physical behavior. I am also interested in LLM interpretation and post-training, knowledge editing, and multi-agent system applications.

In the lab that includes in-hand dexterous manipulation policy training, alongside prototyping low-cost dexterous hands and teleoperation platforms, humanoid control, RGB-D grasping, and state-estimation experiments.

I’m interested in exploring the explainability of AI, and how AI agent systems can make people’s lives more efficient and change current workflows. Previously that meant contributing to Agent Arena’s LLM-powered multi-agent simulation stack. Currently that means contributing to Transnode AI’s AuthenlyUSA credential and identity verification product for hiring and compliance workflows.

Experience

Chronology

Transnode AI

San Diego, CA Jul 2026 – Present

CTO & Co-Founder — AuthenlyUSA

  • Shipping full-stack features on AuthenlyUSA, Transnode’s AI credential & identity verification product for hiring and compliance workflows.
  • Built admin review tooling: rejection notes, secondary staff review, document sorting/filters, and expiry-reminder flows used in live verification operations.
  • Improved candidate subscription & billing UX — cancel-at-period-end, expiry reset, pricing/CTA consistency — across React/TypeScript surfaces on a production SaaS codebase.

Partners & programs
NSF I-CORPS™
IBM Startup Partner Plus
Notion for Startups
Atlassian for Startups
Apple Small Business Program
UC Launch Accelerator
Google for Startups Cloud
BBB Accredited Business

AuthenlyUSA trusted network
LinkedIn
indeed
glassdoor
ZipRecruiter
UC San Diego

National Student Clearinghouse
Parchment
CeCredential Trust
Checkr
Coursera
Regula
Agent Arena

Cambridge, MA · AI Agent Simulator Mar 2026 – Present

Member of Technical Staff

  • Translated product needs into an LLM-powered multi-agent simulation system with Python & FastAPI; work supported acquisition of real paid startup customers.
  • Integrated MinIO (S3-compatible) object storage for scalable multi-file user workflows across simulation sessions.
  • Diagnosed long-context LLM blocking failures and implemented timeout/recovery logic, cutting worst-case pipeline blocking by 96.7% (300s → 10s).

Trusted by leading institutions

Harvard Kennedy School
MIT
BU Questrom
C10 Labs
NVIDIA Inception

UC San Diego

Wang Lab · Robotics Research Sep 2025 – Present

Research — Dexterous Hand & Teleoperation

  • Built a neural optimization pipeline (PyTorch + NVIDIA Warp) using forward kinematics and human finger-motion data to explore low-cost dexterous hand designs for manipulation and teleop.
  • Closed the Sim2Real gap with SDF-based collision metrics; cut inter-finger collision cases in the physical 3D-printed prototype by 50%.
  • Assembled a Gello-based teleoperation platform (YAM arm, Dynamixel actuators) and upstreamed CAD/spec fixes via open-source PR.

Organization

UC San Diego

AdventureX 2025

Hangzhou, China · Advx25 Hackathon Jul 2025 – Aug 2025

Hardware–Software Lead — AI Earphone Prototype (Lumen)

  • Built a vision-enabled AI earphone prototype in three days: ESP32 camera, Bluetooth, speaker output, mobile triggering, and LLM connectivity.
  • Led end-to-end hardware–software integration (ring wake-up, capture, BLE chunked transfer, phone-side processing) and refined product scenarios with investors and mentors.

Event

AdventureX 2025

Baidu

Beijing, China Apr 2024 – Jun 2024

LLM Agent Engineering / Testing Intern

  • Built evaluation workflows and result-checking logic for an LLM spreadsheet-processing agent — reliability, format consistency, downstream compatibility.
  • Scaled multi-threaded Python evaluation pipelines and structured test datasets to accelerate R&D decisions.

Organization

Baidu

AIR, Tsinghua University

Beijing, China 2020 – 2024

Research Assistant — Perception & 3D Learning

  • Designed an LLM-based active-perception policy with memory for indoor object localization (~3× efficiency vs. strongest baseline SPL).
  • Co-developed SNAKE (NeurIPS 2022 Spotlight): shape-aware self-supervised 3D keypoint fields with up to 85% repeatability.
  • Built IEEE CYBER 2024 Best Poster interactive grasping pipeline (ROS + RGB-D + point clouds) for crowded shelf retrieval.

SNAKE collaborators & venues

Tsinghua University
AIR, Tsinghua
Peking University
Intel Labs
MIT
Renmin University of China
NeurIPS 2022

Projects

Selected experiments
ROSManipulationBest Poster

Interactive Grasping in Crowds

Closed-loop retrieval in cluttered shelves — perception, interactive planning, and grasp execution. IEEE CYBER 2024 Best Poster.

MuJoCoLocomotion

Humanoid Walking in MuJoCo

Studying balance, contact forces, and whole-body control strategies for stable humanoid locomotion in simulation.

HackathonESP32LLMAdvx25

AI-Powered Earphone Prototype

Three-day Advx25 build: camera, Bluetooth, speaker, and LLM connectivity for vision-aware conversational assistance — hardware–software end-to-end.

AdventureX 2025
EmbeddedMech3rd Prize

Dual-Friction-Wheel Launcher

Remote-control siege robot with dual friction-wheel launcher — chassis, transmission, motor control, and power. Tsinghua SIEGE 3rd Prize.

Coming soon
WarpOptimizationSim2Real

Optimization-Driven Robotic Hand

Neural design search for printable dexterous hands; SDF collision objectives to make physical prototypes safer for teleoperation.

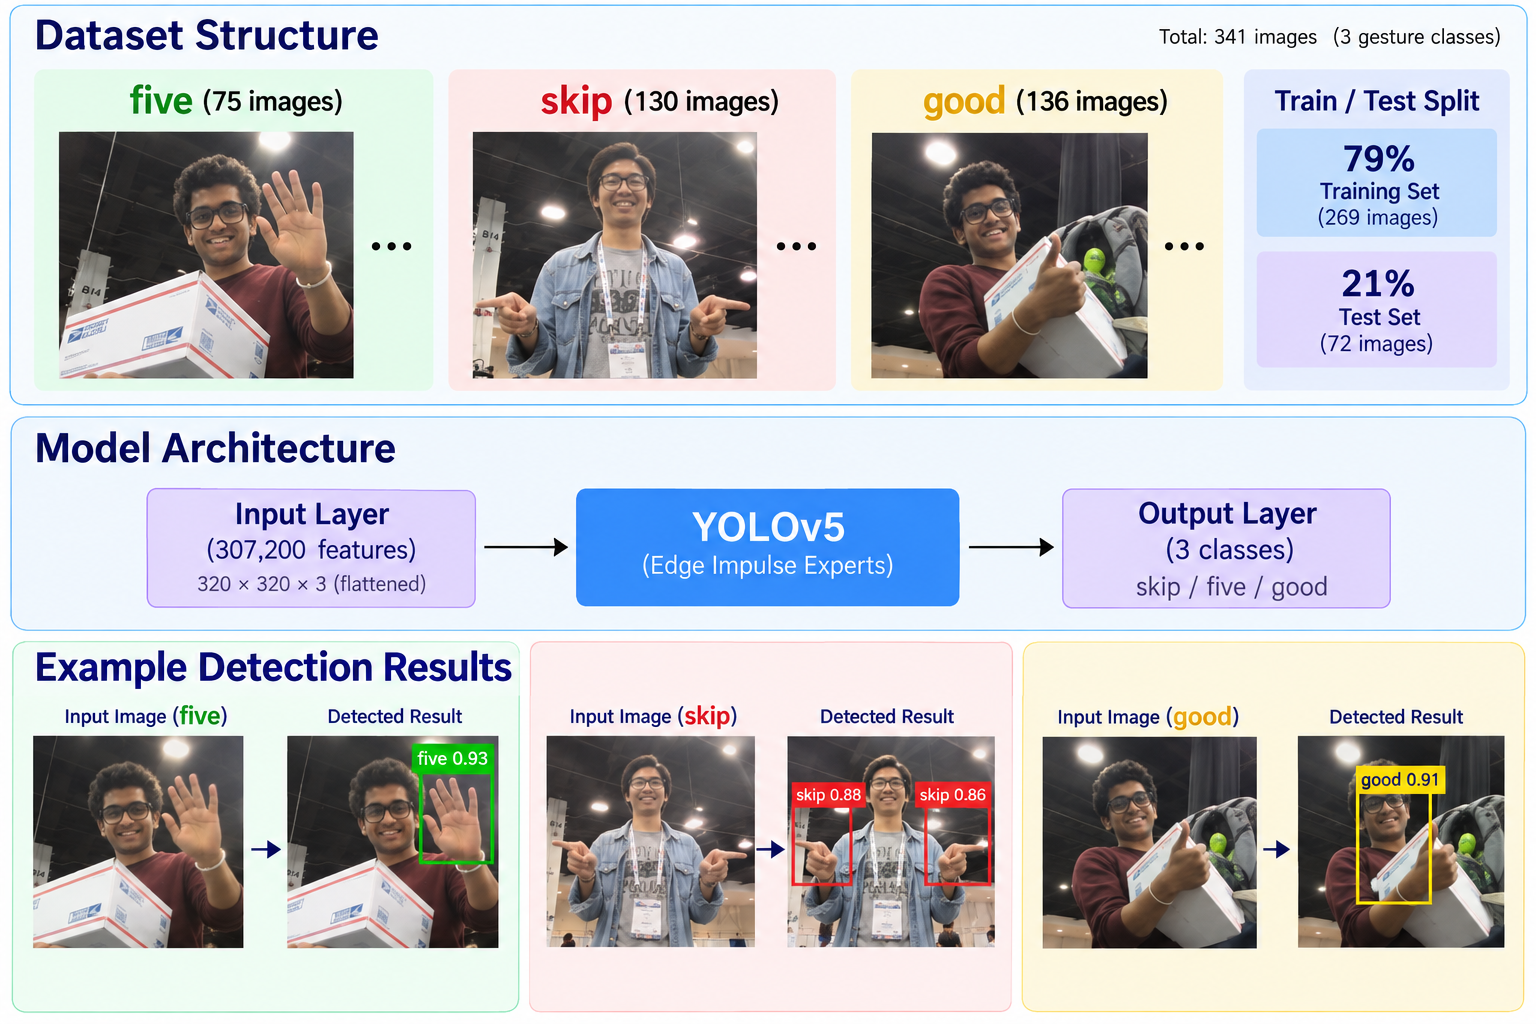
CRATE dataset and YOLOv5 detections for open palm, skip, and thumbs-up
Edge AIYOLOv5EmbeddedHackathon

CRATE — Touchless Gesture Control

On-device YOLOv5 hand gestures for confirm, skip, and cancel when both hands are full. EWNA 2026 Edge AI Hackathon, Industrial Automation first prize.

Skills

Toolkit

Languages

Python, C++, TypeScript, Java, SQL, Embedded C

Frontend / Backend

React, REST APIs, FastAPI, auth, databases, object storage, logging, timeout handling

Robotics & Sim

ROS, MuJoCo, Isaac Gym, PID/LQR, manipulation, navigation, diffusion policy, VLA

AI / ML

LLM agents, PEFT, representation learning, RL, imitation learning, PyTorch, NVIDIA Warp

Embedded

ISRs, PWM motor control, IMU estimation, Bluetooth, hardware–software integration

Infra

Linux, Git, Docker, AWS, MinIO / S3

Publications & Honors

Ink that stuck
  1. Peixing You, Hang Li, et al. (2024). “An Adapter for Interactive Object Retrieval on the Shelf.” IEEE CYBER 2024. doi:10.1109/CYBER63482.2024.10749016 · project page
  2. Peixing You, Chengliang Zhong, et al. (2022). “SNAKE: Shape-aware Neural 3D Keypoint Field.” NeurIPS 2022 (Spotlight). PDF
  • EWNA 2026 Edge AI Hackathon First Prize, Industrial Automation — CRATE
  • IEEE CYBER 2024 Best Poster Award
  • NeurIPS 2022 Spotlight Paper
  • Tsinghua Science & Technology Innovation Excellence Scholarship (Top 1%)
  • Tsinghua Learning Progress Scholarship (Top 1%)
  • Tsinghua Siege Robotic Competition — Third Prize

Contact

Leave a note

Open to research collaborations, robotics / AI systems roles, and interesting prototype problems. Say hello.